SmartGen HGM9560
Mains supervision controller
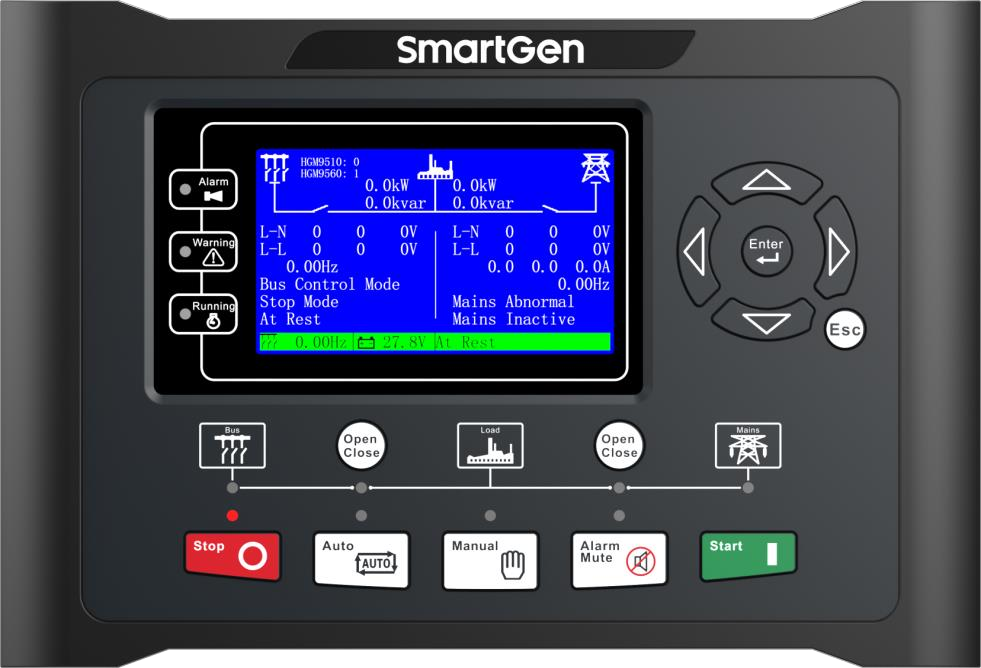
HGM9560 supervises mains and busbar conditions in a parallel-generator installation. Its published protocol distinguishes mains measurements from busbar measurements. Modelling those two electrical locations separately makes its data useful for plant monitoring and import/export analysis.
- Modbus RTU
Mains supervision controller
Compatibility
Documented Modbus RTU interface
One RS-485 Modbus RTU slave interface; separate CAN MSC coordination link
HGM9560 is a mains and busbar controller rather than an engine controller. Its status table includes switch, mains and genset state fields; label them by plant position instead of treating all values as engine telemetry.
Connect it with
-
Modbus Interface ZMB-3XFrom €399 ex VAT Configure Modbus Interface
-
Gateway ZGW-20From €899 ex VAT Configure Gateway
When the documented monitoring interface is fitted and configured
- Modbus
- Edge
- Platforms
Models
| Models | Interface | Route into Edge |
|---|---|---|
| HGM9560 | One RS-485 Modbus RTU slave interface; separate CAN MSC coordination link | Record the controlled breaker and the voltage sensing locations. Match the RS-485 serial format, then read mains frequency using FC03 at decimal offset 64. Compare it with the mains frequency display before adding busbar values. |
Specifications
HGM9560 is a mains and busbar controller rather than an engine controller. Its status table includes switch, mains and genset state fields; label them by plant position instead of treating all values as engine telemetry.12
- Plant role
- Mains supervision controller1
- Monitoring and configuration
- One RS-485 Modbus RTU slave interface; separate CAN MSC coordination link2
- Model distinction
- HGM9560 is a mains and busbar controller rather than an engine controller. Its status table includes switch, mains and genset state fields; label them by plant position instead of treating all values as engine telemetry.12
- Panel protection
- IP55 with the specified panel gasket.1
Interface
Documented measurements and integration boundaries for HGM9560.
- Mains and busbar voltage and frequency measurements
- Switch position, mains state and controller alarms
- Electrical power quantities defined for the connected measurement inputs
Assessment
One RS-485 Modbus RTU slave interface; separate CAN MSC coordination link
- InteroperabilitySupported with conditions
- One RS-485 Modbus RTU slave interface; separate CAN MSC coordination link12
- AccuracySupported with conditions
- The documentation identifies electrical and operating measurements for this plant role. CT configuration and measurement location determine how those values are used.12
- SecurityNot yet assessed
- The cited documentation does not establish an authenticated, encrypted Edge monitoring connection.
- ReliabilityNot yet assessed
- The controller application distinguishes operating conditions and alarms. Retain communication availability alongside the plant readings.
- RuggednessSupported with conditions
- IP55 with the specified panel gasket.1
- ScalabilityNot yet assessed
- Assign one device identity per controller and keep generator, mains and busbar measurements separate.
Setup
Read mains frequency
Best-effort starting point from the retained SmartGen protocol. Confirm the serial settings and compare this first read with the controller display.
- Source
- HGM9560 protocol V1.2, 3 January 2024, page 16
- Function
- 03, read holding registers; quantity 1
- Address convention
- Table 0064 / reference 40065 means decimal PDU offset 64 (0x0040)
- Request PDU
- 03 00 40 00 01
- Decode
- One 16-bit word, scale 0.01 Hz. Example 0x1388 = 5000 = 50.00 Hz.
Acceptance: Compare the decoded mains frequency with the mains display, rather than the busbar frequency field.
-
Record the controlled breaker and the voltage sensing locations.
Match the RS-485 serial format, then read mains frequency using FC03 at decimal offset 64. Compare it with the mains frequency display before adding busbar values.
-
Record CT ratios and the physical measurement location.
Compare the first electrical values with the controller display before using them in totals or trends.
-
Keep missing responses distinct from a stopped generator.
Store communication availability beside running state so a disconnected cable does not look like healthy standby.
-
Build a read-only point list for monitoring.
Remote start, synchronisation and breaker operation require a separate control design with the existing panel interlocks and feedback.
Related devices
Sources
Further reading
Product names and trademarks belong to their owners. Publication does not imply endorsement or a commercial relationship.